AIDepth
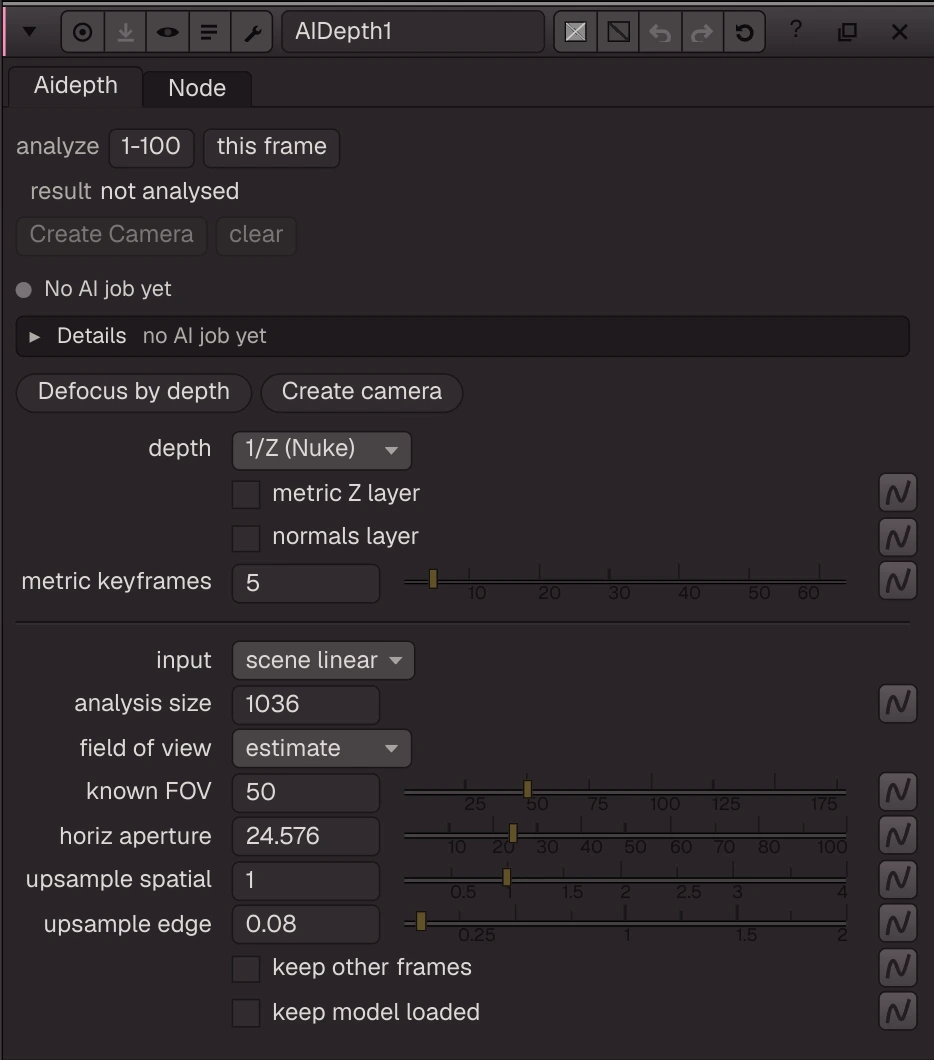
AIDepth: Analyze runs Video Depth Anything Small (Apache-2.0, temporally stable) over the frames and aligns it to MoGe-2 (MIT) metric depth on a few keyframes.
AIDepth: Analyze runs Video Depth Anything Small (Apache-2.0, temporally stable) over the frames and aligns it to MoGe-2 (MIT) metric depth on a few keyframes. Output: depth layer (1/Z like ScanlineRender, or Z), optional depth_metric and N (camera-space normals), upsampled to the plate with a plate-guided filter. Create Camera makes a Camera with the estimated focal length. Model: Auto uses MoGe-2 ViT-B (measured as good as ViT-L and 4x faster); ViT-L is an optional download. Field of view, first that applies: Known FOV (when Field of View is set to known), a Camera on the cam input, the plate's header metadata, then the MoGe-2 estimate. Analyze on 1 to 3 frames keeps the models loaded, so the next frame is fast.
| Node | AIDepth |
|---|---|
| Type id | OC_N_aidepth |
| Menu | AI › AIDepth |
| Nuke class | none: saved in .nk files as an Oink node |
| Code | opencomp_core/nodes/ai/aidepth.py |
Inputs and outputs
| Port | Name | Type |
|---|---|---|
| input 0 | Image | image |
| input 1 | cam | scene |
| output 0 | Image | image |
Knobs
Panel tab Aidepth, in panel order.
| Knob | Label | Type | Default | Range / values | Nuke knob | Description |
|---|---|---|---|---|---|---|
depth_convention | depth | menu | inv | inv (1/Z (Nuke)), z (Z) | ||
output_metric | metric Z layer | bool | false | Also output depth_metric (.r = Z metres) | ||
output_normals | normals layer | bool | false | Also run MoGe-2 on every frame for an N layer | ||
keyframes | metric keyframes | float | 5 | 1 to 64 (integer) | Frames MoGe-2 measures for the metric scale / shift fit | |
encode | input | menu | srgb | srgb (scene linear), none (display) | ||
analysis_width | analysis size | float | 1036 | 256 to 2048 (integer) | Long side of the frames sent to the model (px) | |
fov_mode | field of view | menu | estimate | estimate, known | ||
known_fov | known FOV | float | 50 | 1 to 179 | ||
haperture | horiz aperture | float | 24.576 | 0.1 to 100 | Film back width (mm) for the focal readout / Create Camera | |
spatial_sigma | upsample spatial | float | 1 | 0.1 to 4 | Joint bilateral spatial sigma (model pixels) | |
range_sigma | upsample edge | float | 0.08 | 0.005 to 2 | Joint bilateral range sigma (plate colour, lower = sharper edges) | |
keep_other_frames | keep other frames | bool | false | Analyze keeps results of frames outside the new range | ||
keep_loaded | keep model loaded | bool | false | Leave the models in VRAM after Analyze (faster re-runs) |
Other knobs (Python, .nk and the assistant; not on the panel)
| Knob | Label | Type | Default | Range / values | Nuke knob | Description |
|---|---|---|---|---|---|---|
gl_color | Viewer Controls Color | float ×3 | 0, 0, 0 | 0 to 1 | ||
postage_stamp_frame | Static Frame | int | 1 | -2147483648 to 2147483647 | ||
lifetimeStart | Lifetime Start | int | 0 | -2147483648 to 2147483647 | ||
lifetimeEnd | Lifetime End | int | 100 | -2147483648 to 2147483647 | ||
useLifetime | Use Lifetime | boolean | false | |||
cached | Cached | boolean | false | |||
bookmark | Bookmark | boolean | false | |||
dope_sheet | Dope Sheet | boolean | false | |||
clone_group | Clone Group | string | ||||
link_source | Link Source | string | ||||
link_overrides | Link Overrides | string | ||||
split_views | Split Views | string | ||||
moge_model | Model | enum | AUTO | AUTO, VITL, VITB | Geometry model (metric depth, field of view, normals); licence tier: optional / bundled | |
results_data | Results | string | {} | |||
fov_x | FOV X (deg) | float | 0 | -3.4028234663852886e+38 to 3.4028234663852886e+38 | ||
fov_y | FOV Y (deg) | float | 0 | -3.4028234663852886e+38 to 3.4028234663852886e+38 | ||
focal | Focal (mm) | float | 0 | -3.4028234663852886e+38 to 3.4028234663852886e+38 | ||
analysed_first | Analysed First | int | 0 | -2147483648 to 2147483647 | ||
analysed_last | Analysed Last | int | -1 | -2147483648 to 2147483647 | ||
fit_scale | Fit Scale | float | 0 | -3.4028234663852886e+38 to 3.4028234663852886e+38 | ||
fit_shift | Fit Shift | float | 0 | -3.4028234663852886e+38 to 3.4028234663852886e+38 | ||
fit_error | Fit Error | float | 0 | -3.4028234663852886e+38 to 3.4028234663852886e+38 | Median relative depth error of the fit on the keyframes |
Nuke equivalent
No Nuke class. In a .nk file this node is written as an Oink node that Nuke will not recognise.
AIRoto
AIRoto: click on the plate in the Viewer to add an object (Shift/Alt+click removes, drag draws a box); the mask shows at once.
AINormals
AINormals: Analyze runs MoGe-2 (MIT) per frame: N layer = normals in camera space (X right, Y up, +Z to camera), or world space when a camera is connected to cam.