Nodes
CameraTracker
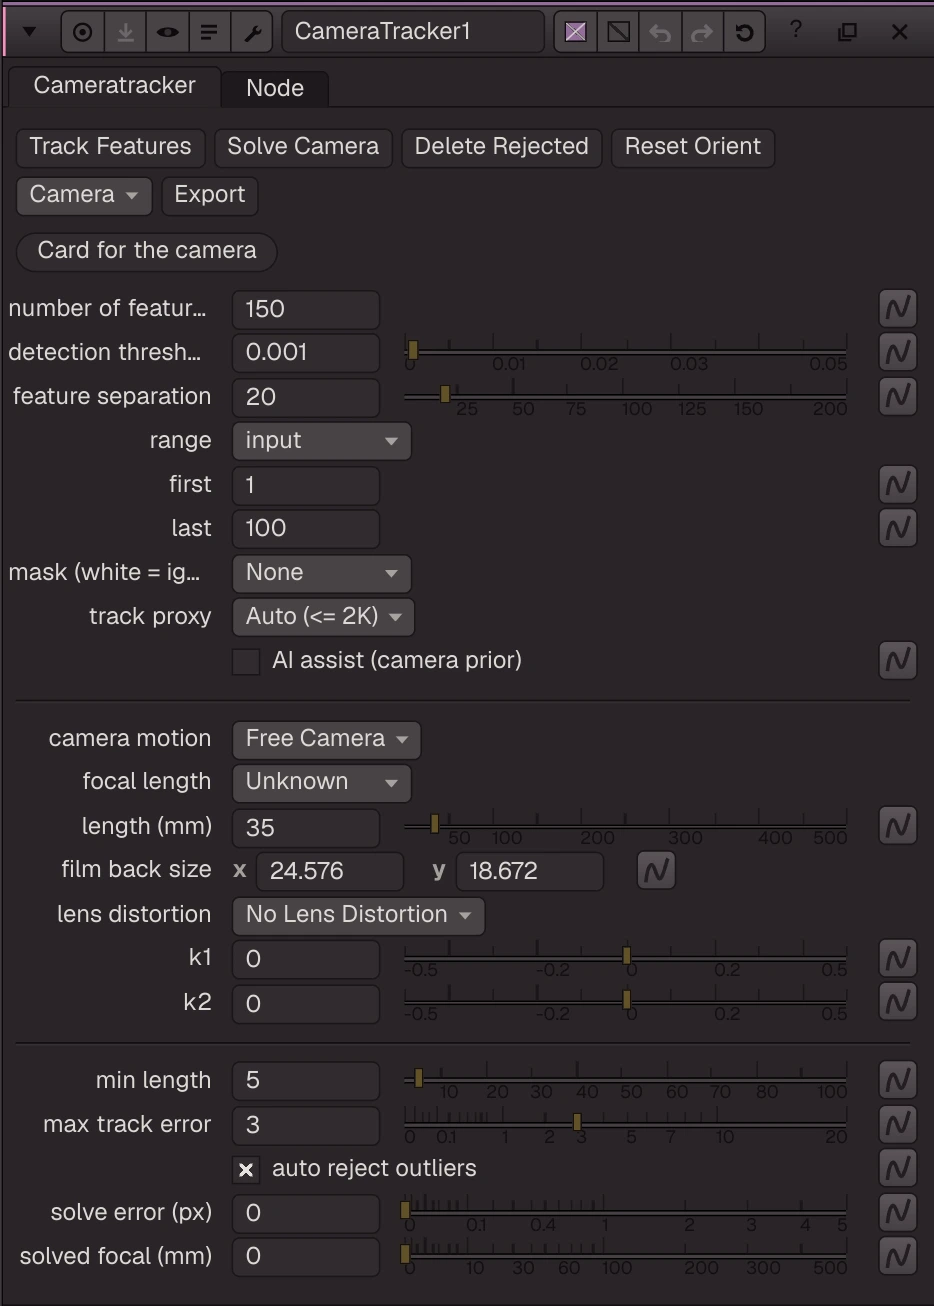
CameraTracker (NukeX): Track Features, then Solve Camera.
CameraTracker (NukeX): Track Features, then Solve Camera. Rejected tracks (error above max track error) are left out; Delete Rejected removes them. Export makes a Camera, point cloud, Scene or Scene+ (with ScanlineRender), or a LensDistortion.
| Node | CameraTracker |
|---|---|
| Type id | OC_N_cameratracker |
| Menu | Transform › CameraTracker |
| Nuke class | CameraTracker |
| Code | opencomp_core/nodes/tracking/camera_tracker.py |
Inputs and outputs
| Port | Name | Type |
|---|---|---|
| input 0 | Source | image |
| input 1 | Mask | image |
| output 0 | Image | image |
Knobs
Panel tab Cameratracker, in panel order.
| Knob | Label | Type | Default | Range / values | Nuke knob | Description |
|---|---|---|---|---|---|---|
number_features | number of features | float | 150 | 8 to 2000 (integer) | number_features | |
detection_threshold | detection threshold | float | 0.001 | 0 to 0.05 | detection_threshold | |
feature_separation | feature separation | float | 20 | 2 to 200 (integer) | feature_separation | |
track_range | range | menu | input | input, custom | ||
range_first | first | float | 1 | -100000 to 100000 (integer) | ||
range_last | last | float | 100 | -100000 to 100000 (integer) | ||
mask_mode | mask (white = ignore) | menu | none | none (None), source_alpha (Source Alpha), source_inverted_alpha (Source Inverted Alpha), mask_luminance (Mask Luminance), mask_inverted_luminance (Mask Inverted Luminance), mask_alpha (Mask Alpha), mask_inverted_alpha (Mask Inverted Alpha) | ||
proxy | track proxy | menu | auto | auto (Auto (<= 2K)), full (Full), half (Half), quarter (Quarter) | ||
ai_assist | AI assist (camera prior) | bool | false | |||
camera_motion | camera motion | menu | free | free (Free Camera), rotation (Rotation Only) | ||
focal_length_type | focal length | menu | unknown | known (Known), approximate (Approximate), unknown (Unknown) | ||
focal_length | length (mm) | float | 35 | 1 to 500 | focal_length | |
film_back_size | film back size | vector ×2 | 24.576, 18.672 | 1 to 80 | ||
lens_distortion | lens distortion | menu | no_lens_distortion | no_lens_distortion (No Lens Distortion), unknown (Unknown Lens), known (Known (k1, k2)) | ||
k1 | k1 | float | 0 | -0.5 to 0.5 | k1 | |
k2 | k2 | float | 0 | -0.5 to 0.5 | k2 | |
min_length | min length | float | 5 | 2 to 100 (integer) | min_length | |
max_track_error | max track error | float | 3 | 0 to 20 | max_track_error | |
auto_reject | auto reject outliers | bool | true | |||
solve_error | solve error (px) | float | 0 | 0 to 5 | ||
focal_solved | solved focal (mm) | float | 0 | 0 to 500 |
Other knobs (Python, .nk and the assistant; not on the panel)
| Knob | Label | Type | Default | Range / values | Nuke knob | Description |
|---|---|---|---|---|---|---|
gl_color | Viewer Controls Color | float ×3 | 0, 0, 0 | 0 to 1 | ||
postage_stamp_frame | Static Frame | int | 1 | -2147483648 to 2147483647 | ||
lifetimeStart | Lifetime Start | int | 0 | -2147483648 to 2147483647 | ||
lifetimeEnd | Lifetime End | int | 100 | -2147483648 to 2147483647 | ||
useLifetime | Use Lifetime | boolean | false | |||
cached | Cached | boolean | false | |||
bookmark | Bookmark | boolean | false | |||
dope_sheet | Dope Sheet | boolean | false | |||
clone_group | Clone Group | string | ||||
link_source | Link Source | string | ||||
link_overrides | Link Overrides | string | ||||
split_views | Split Views | string | ||||
num_tracks | Tracks | int | 0 | -2147483648 to 2147483647 | ||
num_rejected | Rejected | int | 0 | -2147483648 to 2147483647 |
Nuke equivalent
Imports from and exports to Nuke's CameraTracker.
Knobs with a different name here:
| Nuke knob | Knob here |
|---|---|
numberFeatures | number_features |
detectionThreshold | detection_threshold |
featureSeparation | feature_separation |
minLength | min_length |
maxTrackError | max_track_error |
focalLength | focal_length |
Nuke knobs not in this list import as a knob of the same name, or are kept unchanged for export. See .nk import.